I would like to utilize gazebo plugin to build my swerve and I have installed all the required package. But when I launch this file. It keeps getting this error [ERROR] [1680540671.064874967, 0.294000000]: Could not load class 'swerve_steering_controller/SwerveSteeringController': Could not find library corresponding to plugin swerve_steering_controller/SwerveSteeringController. Make sure the plugin description XML file has the correct name of the library and that the library actually exists. [ERROR] [1680540671.064917156, 0.294000000]: Could not load controller 'swerve_steering_controller' because controller type 'swerve_steering_controller/SwerveSteeringController' does not exist. [ERROR] [1680540671.064928889, 0.294000000]: Use 'rosservice call controller_manager/list_controller_types' to get the available types.
May I know how to solve this problem? I am sure all package are installed. THANK YOU
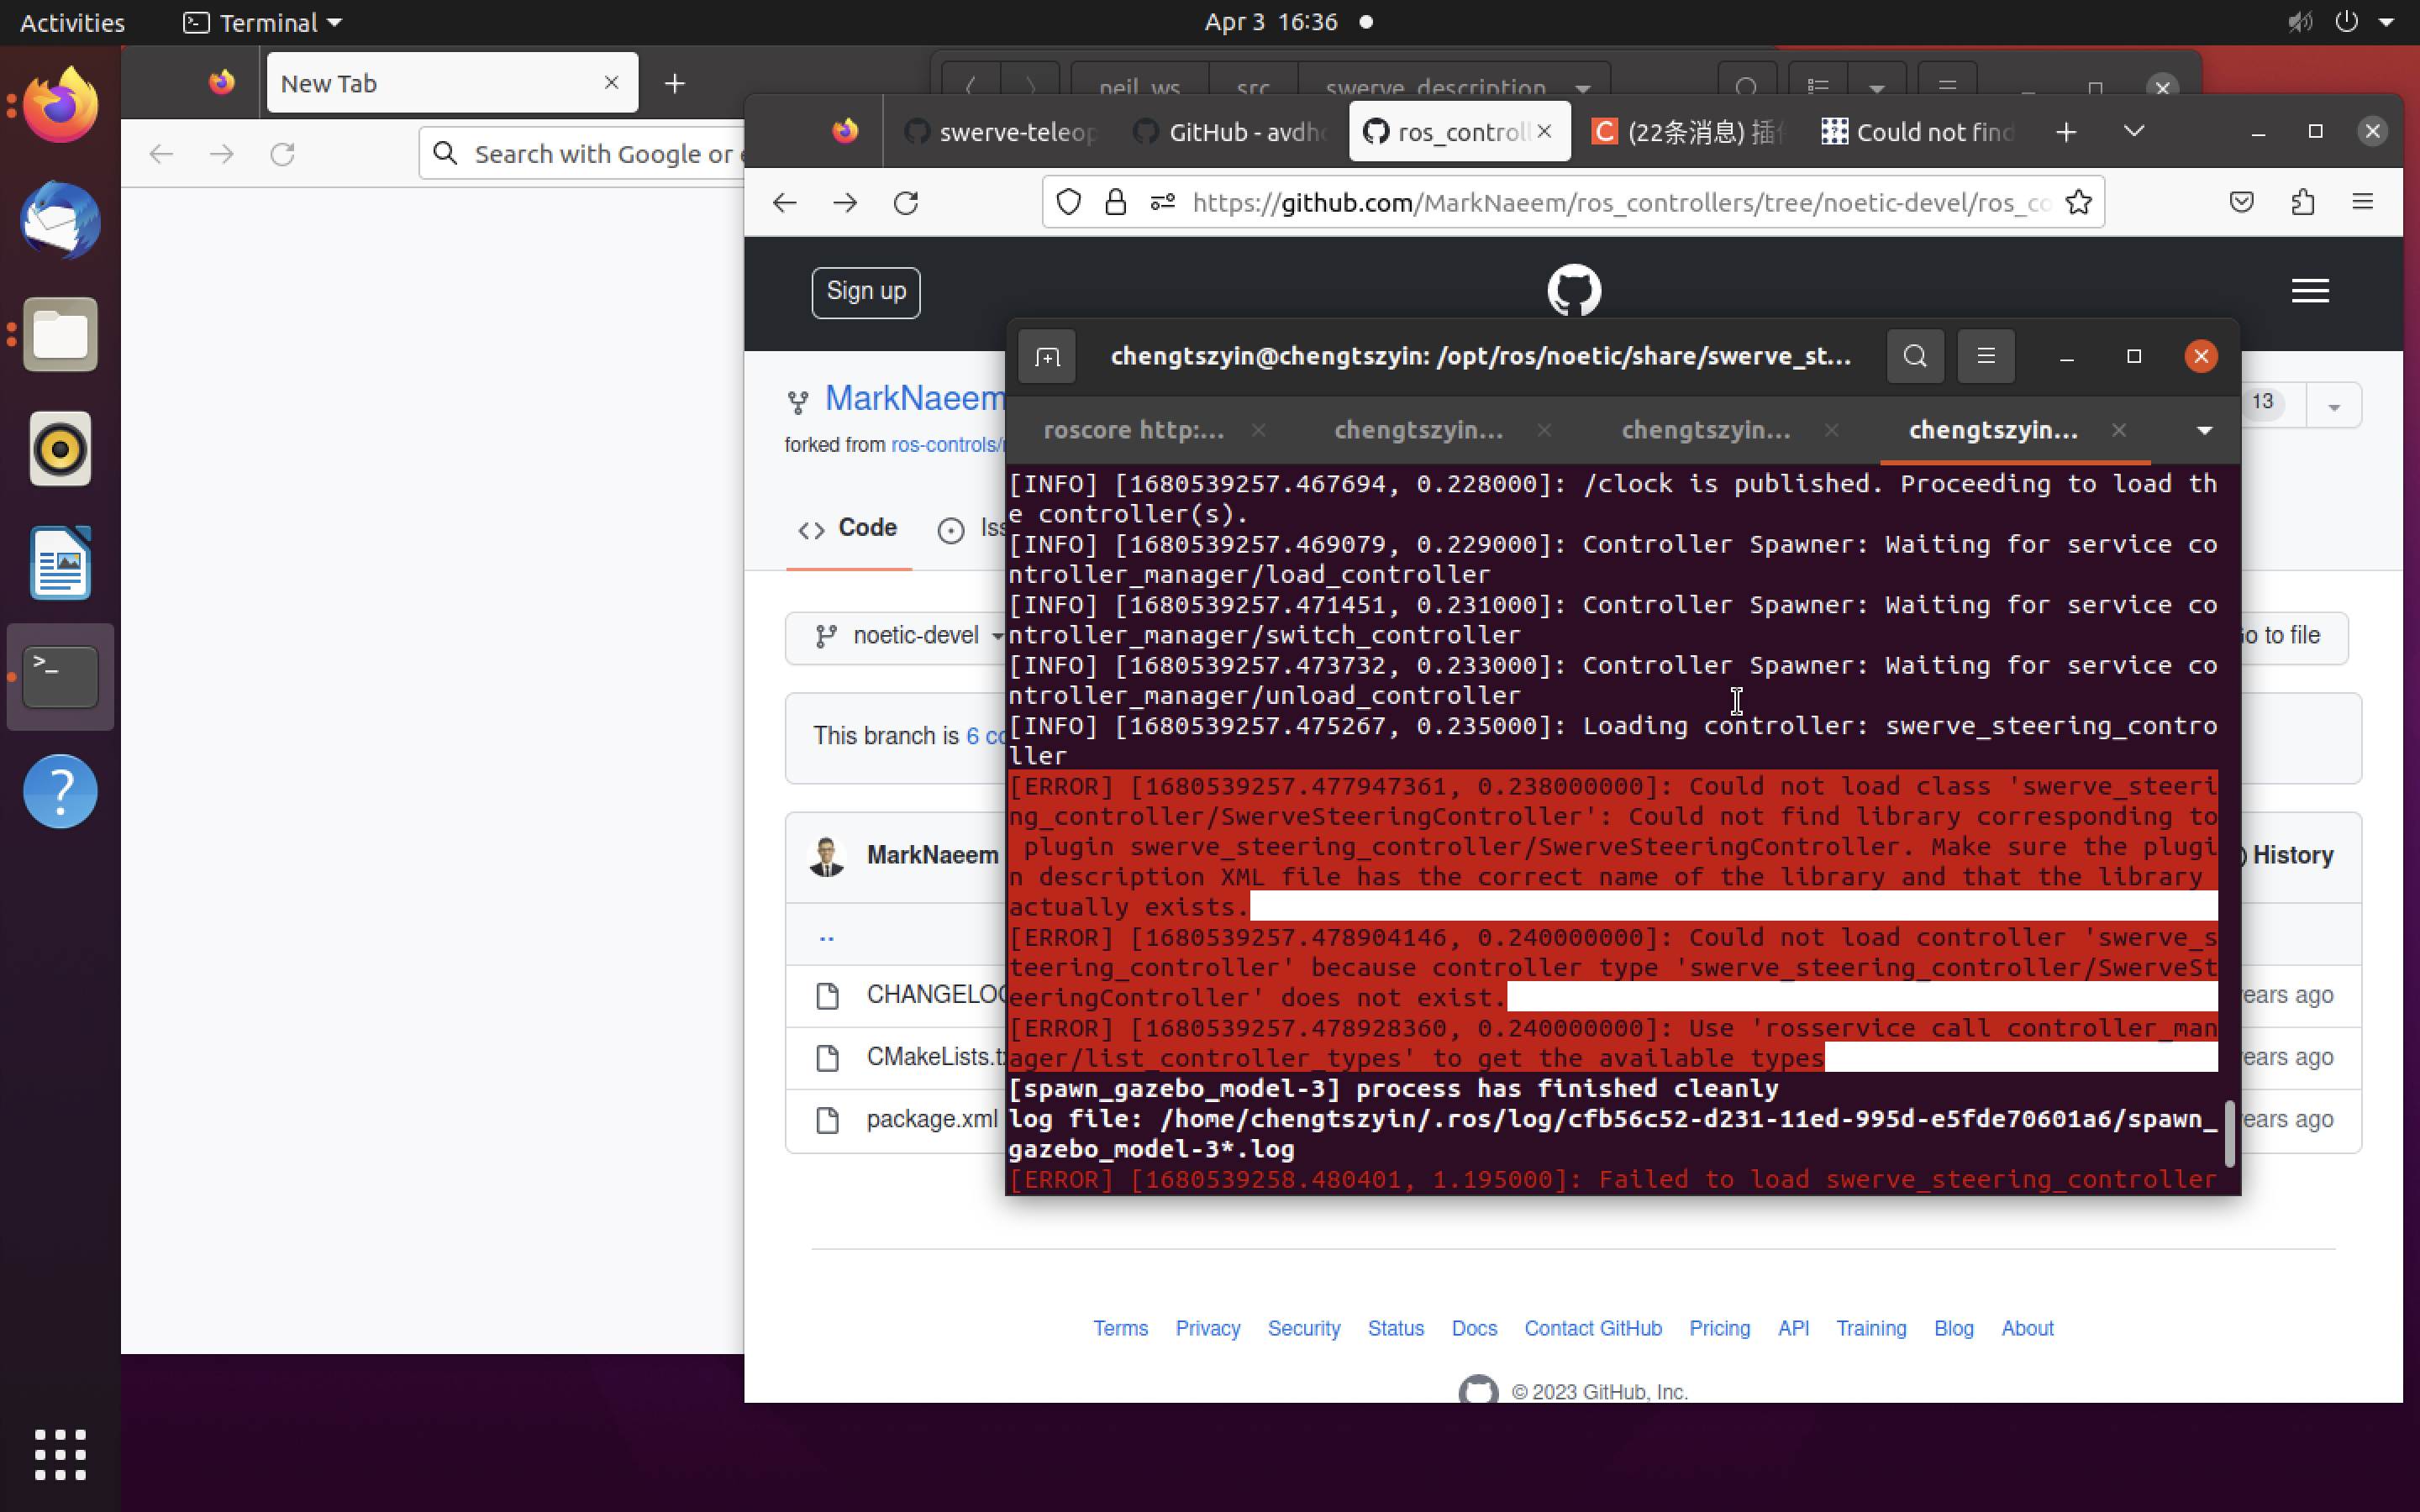
I would like to utilize gazebo plugin to build my swerve and I have installed all the required package. But when I launch this file. It keeps getting this error
[ERROR] [1680540671.064874967, 0.294000000]: Could not load class 'swerve_steering_controller/SwerveSteeringController': Could not find library corresponding to plugin swerve_steering_controller/SwerveSteeringController. Make sure the plugin description XML file has the correct name of the library and that the library actually exists. [ERROR] [1680540671.064917156, 0.294000000]: Could not load controller 'swerve_steering_controller' because controller type 'swerve_steering_controller/SwerveSteeringController' does not exist. [ERROR] [1680540671.064928889, 0.294000000]: Use 'rosservice call controller_manager/list_controller_types' to get the available types.May I know how to solve this problem? I am sure all package are installed. THANK YOU