Repository navigation
Show IMU bias estimates and three-sigma localization uncertainty - #17
Merged
Merged
Conversation


2 of 3 tasks

Owner
Author
|
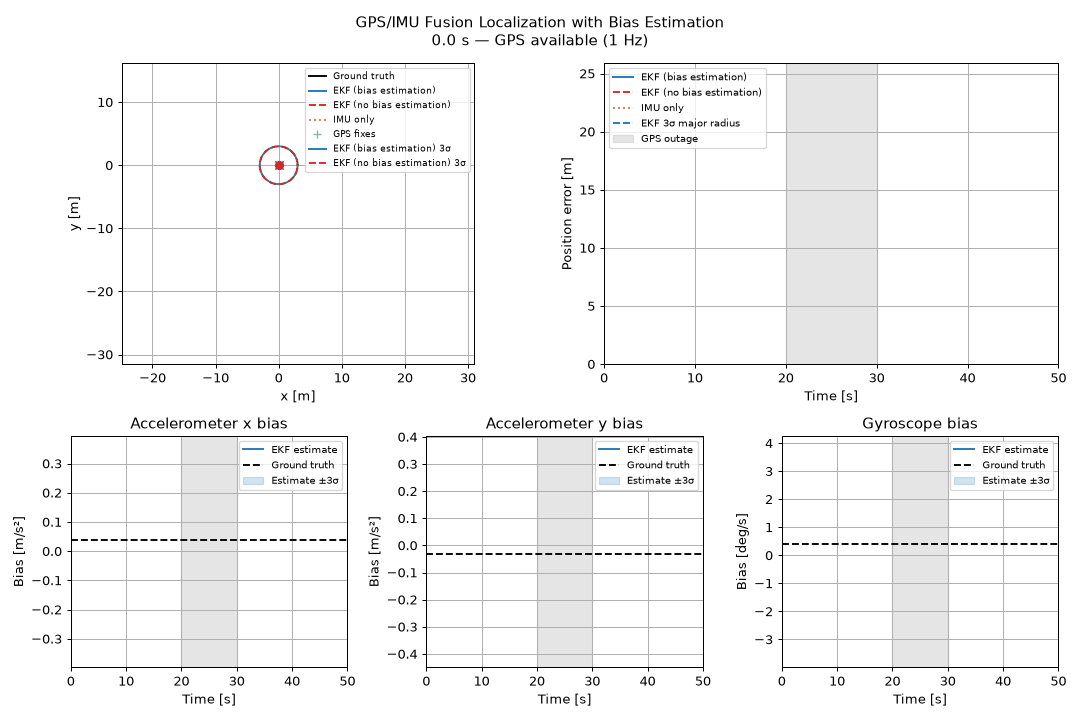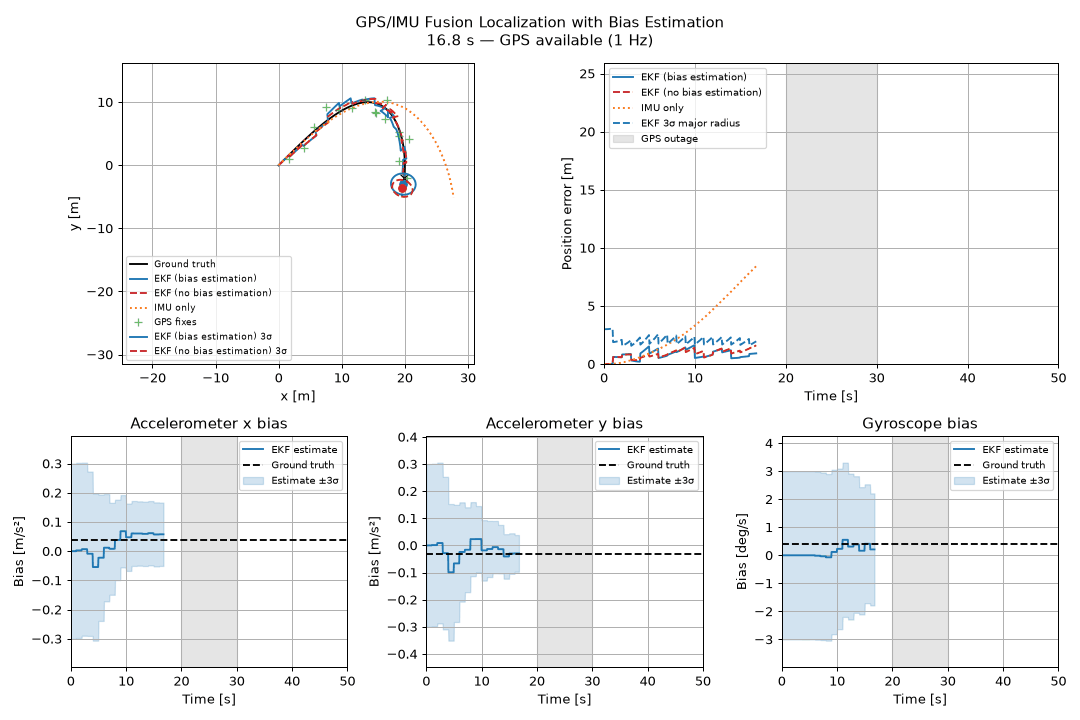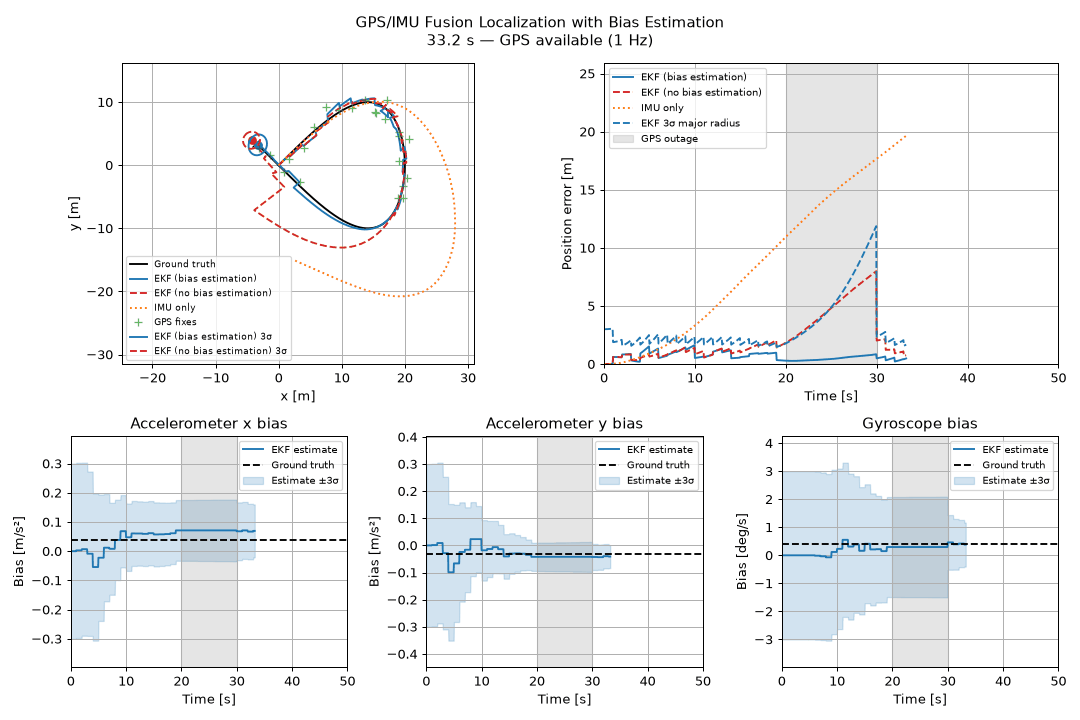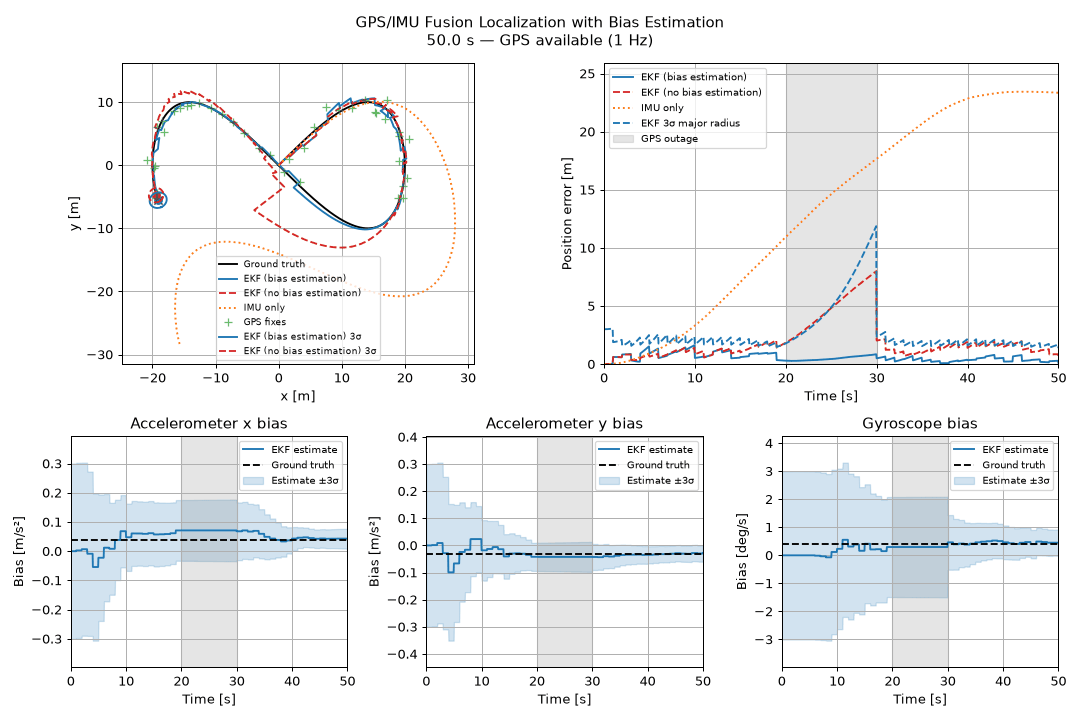
GPS/IMU Fusion Localization with Bias Estimation The upper panels compare GPS/IMU fusion with bias estimation (blue), fusion without bias estimation (red dashed), and IMU-only dead reckoning (orange dotted), using the same sensor measurements.
For the default seed 0, ground truth lies inside the bias-estimating EKF's position ellipse and all three bias bands at all 1,001 samples. The no-bias-estimation EKF's true position falls outside its ellipse during parts of the run. These are synthetic demonstration results, not a guarantee of coverage for other data. The bias 3σ half-widths shrink from 0.300 → 0.0339 m/s² (x), 0.300 → 0.0296 m/s² (y), and 3.000 → 0.458 deg/s (gyro). |
 AtsushiSakai
changed the title
AtsushiSakai
marked this pull request as ready for review
October 4, 2026 16:08
This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters.
Learn more about bidirectional Unicode characters
Sign up for free
to join this conversation on GitHub.
Already have an account?
Sign in to comment
1 participant

Add this suggestion to a batch that can be applied as a single commit.This suggestion is invalid because no changes were made to the code.Suggestions cannot be applied while the pull request is closed.Suggestions cannot be applied while viewing a subset of changes.Only one suggestion per line can be applied in a batch.Add this suggestion to a batch that can be applied as a single commit.Applying suggestions on deleted lines is not supported.You must change the existing code in this line in order to create a valid suggestion.Outdated suggestions cannot be applied.This suggestion has been applied or marked resolved.Suggestions cannot be applied from pending reviews.Suggestions cannot be applied on multi-line comments.Suggestions cannot be applied while the pull request is queued to merge.Suggestion cannot be applied right now. Please check back later.
Update the animation for PythonRobotics#1448 with three panels showing the estimated accelerometer x/y biases (m/s²) and gyroscope bias (deg/s), alongside their true values. The bias plots include covariance-derived ±3σ bands. The trajectory plot shows each EKF's current 3σ position ellipse, including the x/y cross-covariance, and the position-error plot tracks the bias-estimating EKF's ellipse semi-major axis. Gray shading marks the GPS outage in the error and bias plots.
The title is now GPS/IMU Fusion Localization with Bias Estimation to match the documentation.
Generated with
create_animation(simulate(seed=0))and PillowWriter at 20 fps and 90 dpi. Verified all 201 frames at 1080 × 720 pixels and visually checked the GPS-outage and final frames. This follows the previously merged animation PR #15.